Research Areas

Dexterous Manipulation and Grasping
This research focuses on dexterous manipulation and grasping in robotics, combining strategies like edge-rolling, pivoting, and sliding to move heavy objects using environmental contact, optimization-based methods for evaluating grasp quality, and detailed modeling of soft-finger contact mechanics and slippage.
Robotic Hand Design
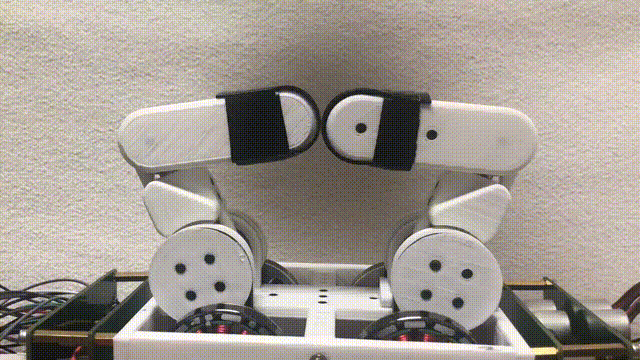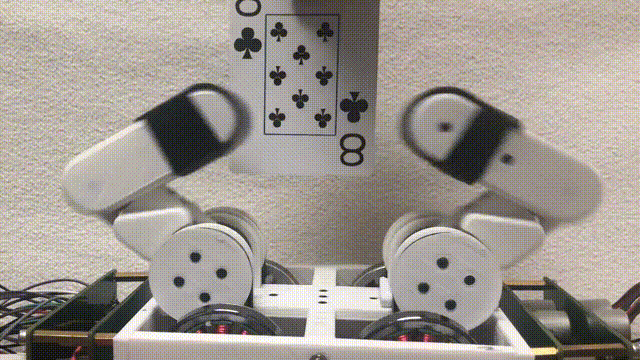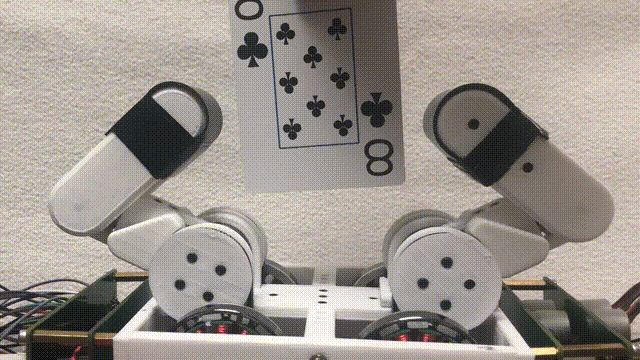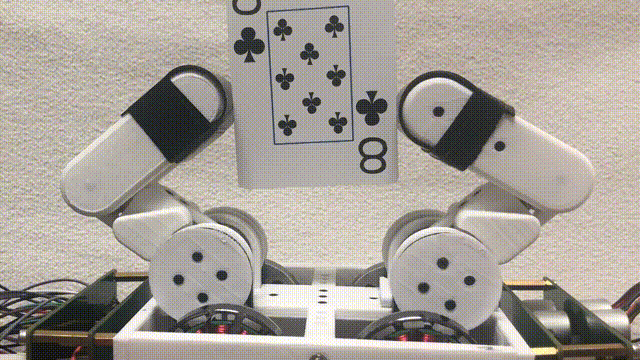
This research introduces a novel two-fingered robotic hand built with quasi-direct-drive actuators and variable impedance control, enabling safe, compliant interaction with unstructured environments without relying on complex force or tactile sensors. The hand demonstrates versatile capabilities, including stable grasping, disturbance recovery, environment-assisted manipulation, and gentle handling of fragile objects.
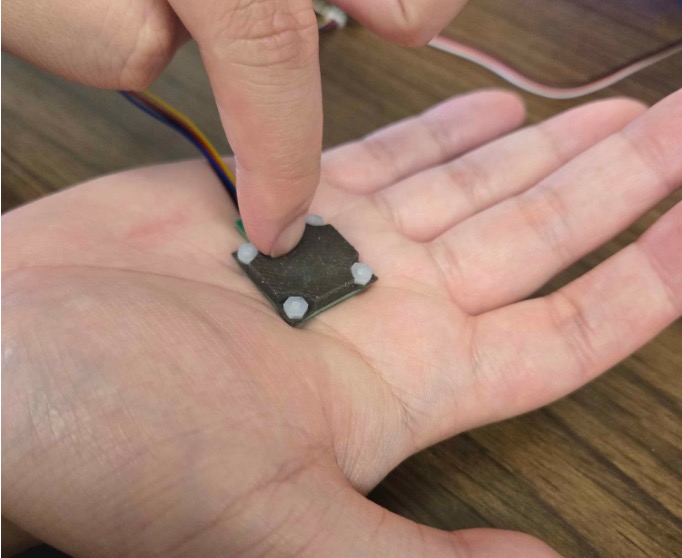
Force Sensor Design
This research develops a soft magnetic tactile sensor using magnetorheological elastomer technology, paired with a novel computational framework that translates Hall-effect sensor readings into tri-axial normal and shear force measurements while precisely localizing contact points. The approach accounts for the material’s non-linear and hysteretic behavior to deliver robust, real-time tactile feedback, enabling accurate slip detection and stable manipulation of delicate objects.
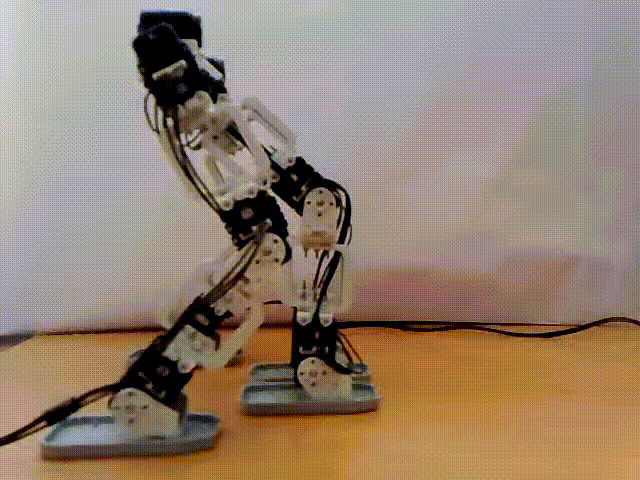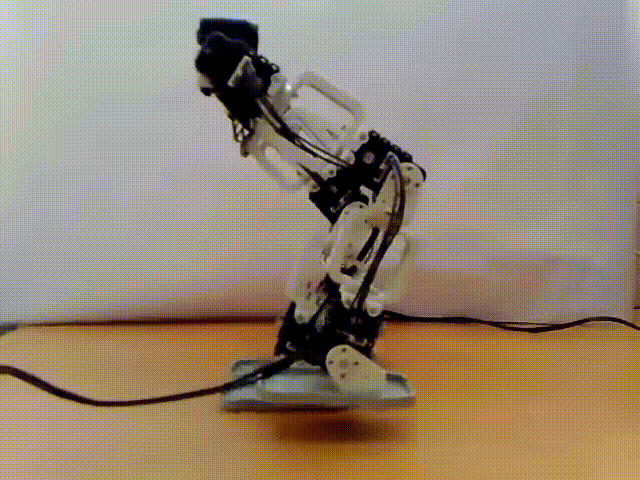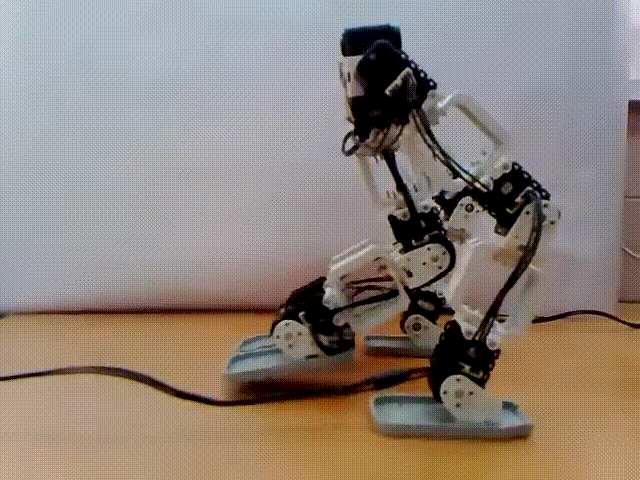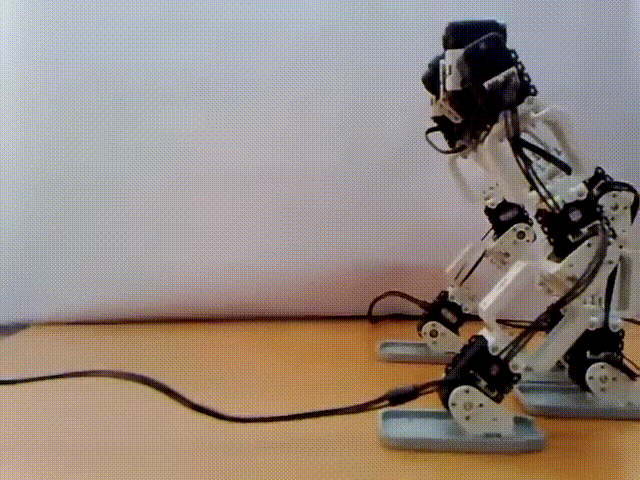
Other Projects
Additional robotics projects, including (i) LinBot, a novel inspection robot designed to autonomously traverse and surmount obstacles on high-voltage power transmission lines using a combination of active and passive roller mechanisms, validated through simulation and real-world field-testing, and (ii) trajectory planning for a seven-link biped robot, developing methods to generate stable, adaptable walking gaits with varying step lengths across different terrain, verified through simulation and experiments.